Author: Osiris

  • The Future of Perimeter Security: Sensor Fusion and AI

    The Future of Perimeter Security: Sensor Fusion and AI

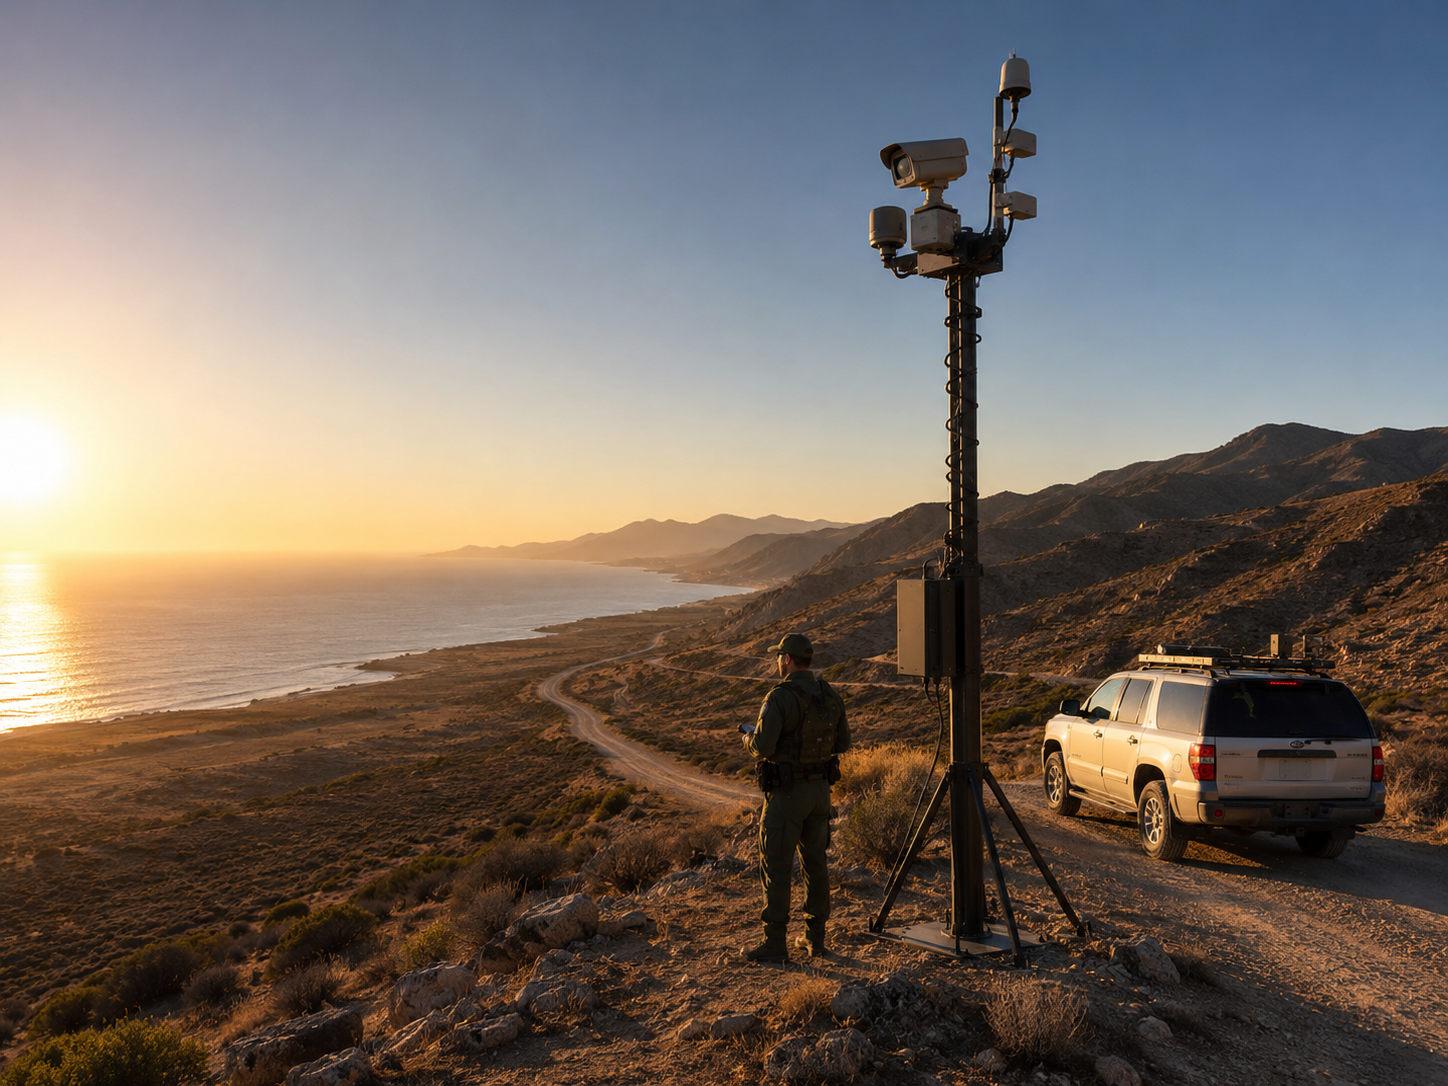
    Perimeter security is moving away from single-sensor thinking. Traditional designs often depended on one primary detection technology, such as fence vibration sensors or video motion detection. Modern systems increasingly combine radar, thermal cameras, visible cameras, fiber-optic sensing, access data and AI analytics to create a richer picture of what is happening around a site.

    Sensor fusion is the key change. A fence vibration may indicate an event, but radar can reveal movement beyond the fence, thermal imaging can detect a person at night and a PTZ camera can provide visual confirmation. When these inputs are correlated automatically, the operator receives a higher-confidence incident instead of several unrelated alarms.

    AI is improving classification rather than simply adding more alarms. Models can distinguish people, vehicles and animals, analyze direction and speed, and prioritize activity that violates site rules. The practical benefit is lower operator workload and fewer nuisance events.

    Fiber-optic sensing is also becoming more important, especially across long pipelines, rail corridors, borders and large industrial perimeters. Distributed sensing can turn kilometers of fiber into continuous detection zones and complement point sensors or cameras.

    Edge computing will further change architecture. More classification can occur near the sensor, reducing bandwidth and enabling faster local decisions. Cloud platforms will remain valuable for fleet management, analytics updates and multi-site visibility.

    The future perimeter will therefore behave less like a collection of independent devices and more like a coordinated detection network. The goal is not maximum sensor count. It is confidence: detect early, classify accurately, verify quickly and present operators with the context required to act.

  • Smart Gates and Vehicle Access Control

    Smart Gates and Vehicle Access Control

    Vehicle entrances are among the most complex points in physical security because they combine identity, traffic flow, safety and perimeter control. A modern smart gate must determine who or what is approaching, whether access is authorized and how to move vehicles through the site without creating congestion or unsafe conditions.

    Common technologies include license-plate recognition, RFID tags, mobile credentials, intercoms, loop detectors, radar, barriers, bollards and video analytics. High-security sites may also add under-vehicle inspection or guard verification.

    The most effective systems link the vehicle to an access policy. A recognized plate alone should not automatically be treated as proof of identity in every environment. The system may also verify a driver credential, delivery schedule, visitor record or vehicle classification.

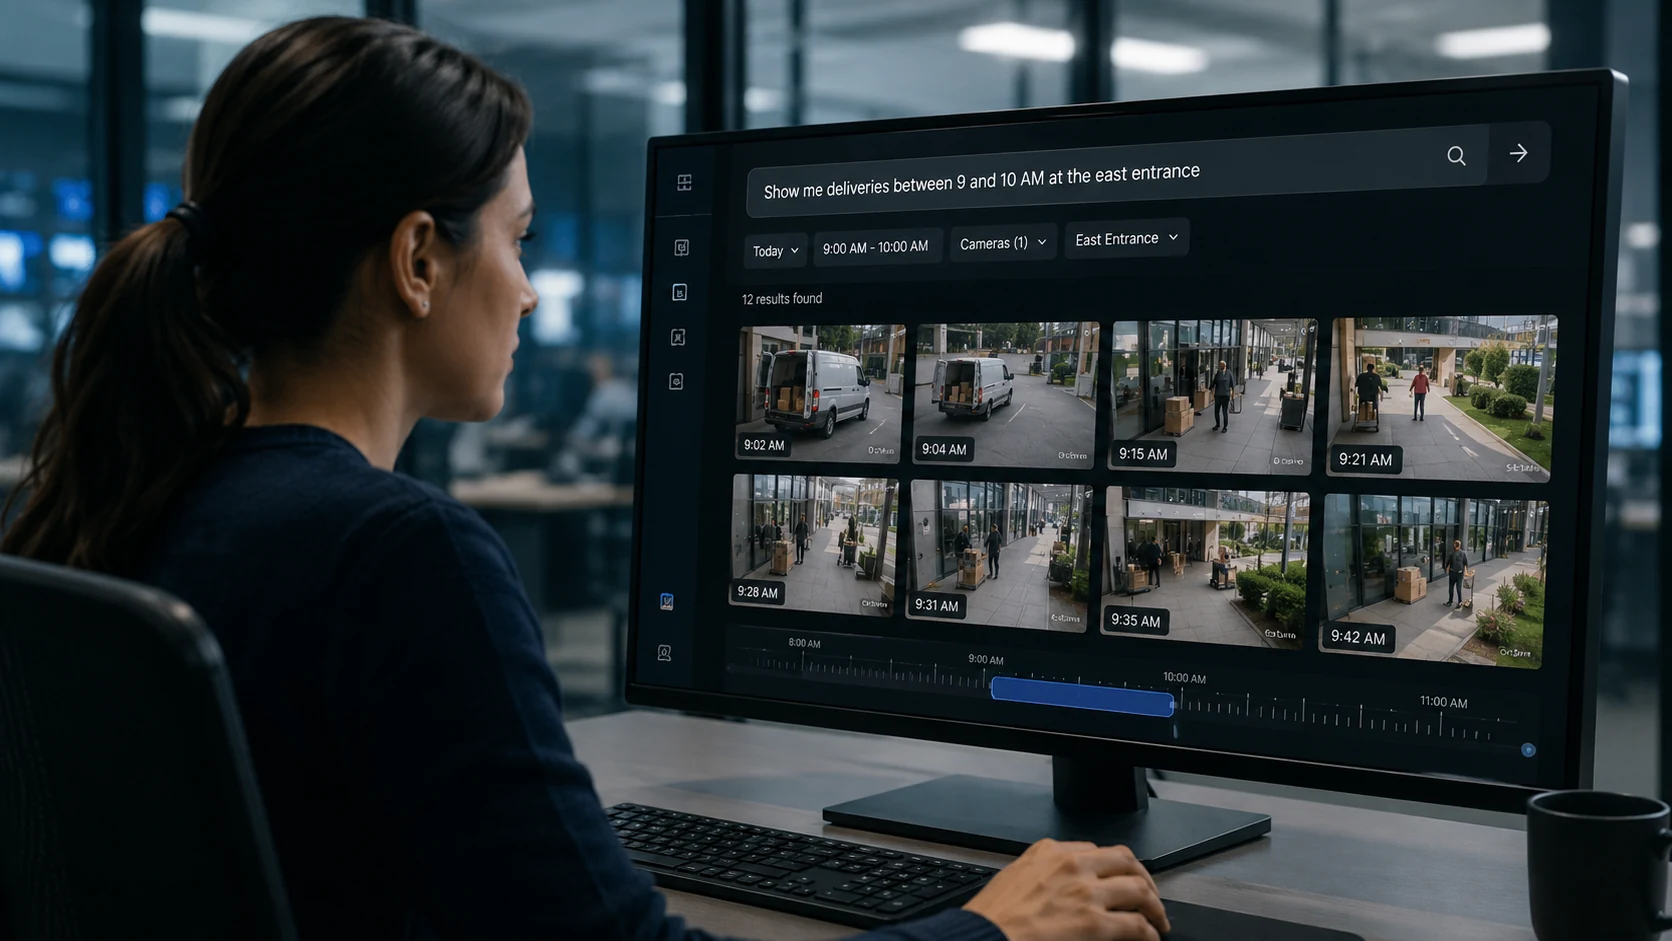
    Video plays a major role in evidence and exception handling. Cameras can document the vehicle, driver lane and surrounding context, while analytics can detect tailgating, wrong-way movement or a vehicle entering a restricted lane.

    Safety must be engineered alongside security. Barrier arms, gates and bollards require presence detection and safe operating logic to avoid collisions. Emergency egress and fire-service access also need dedicated procedures.

    For multi-site organizations, cloud-connected gate management can centralize credentials and audit logs. At critical infrastructure sites, local operation should remain available if connectivity fails.

    Smart vehicle access is therefore not one product but a coordinated system. The strongest designs combine identification, physical barriers, sensors, video and workflow software into one controlled entry process.

  • Security Robots: Where Autonomous Patrol Actually Makes Sense

    Security Robots: Where Autonomous Patrol Actually Makes Sense

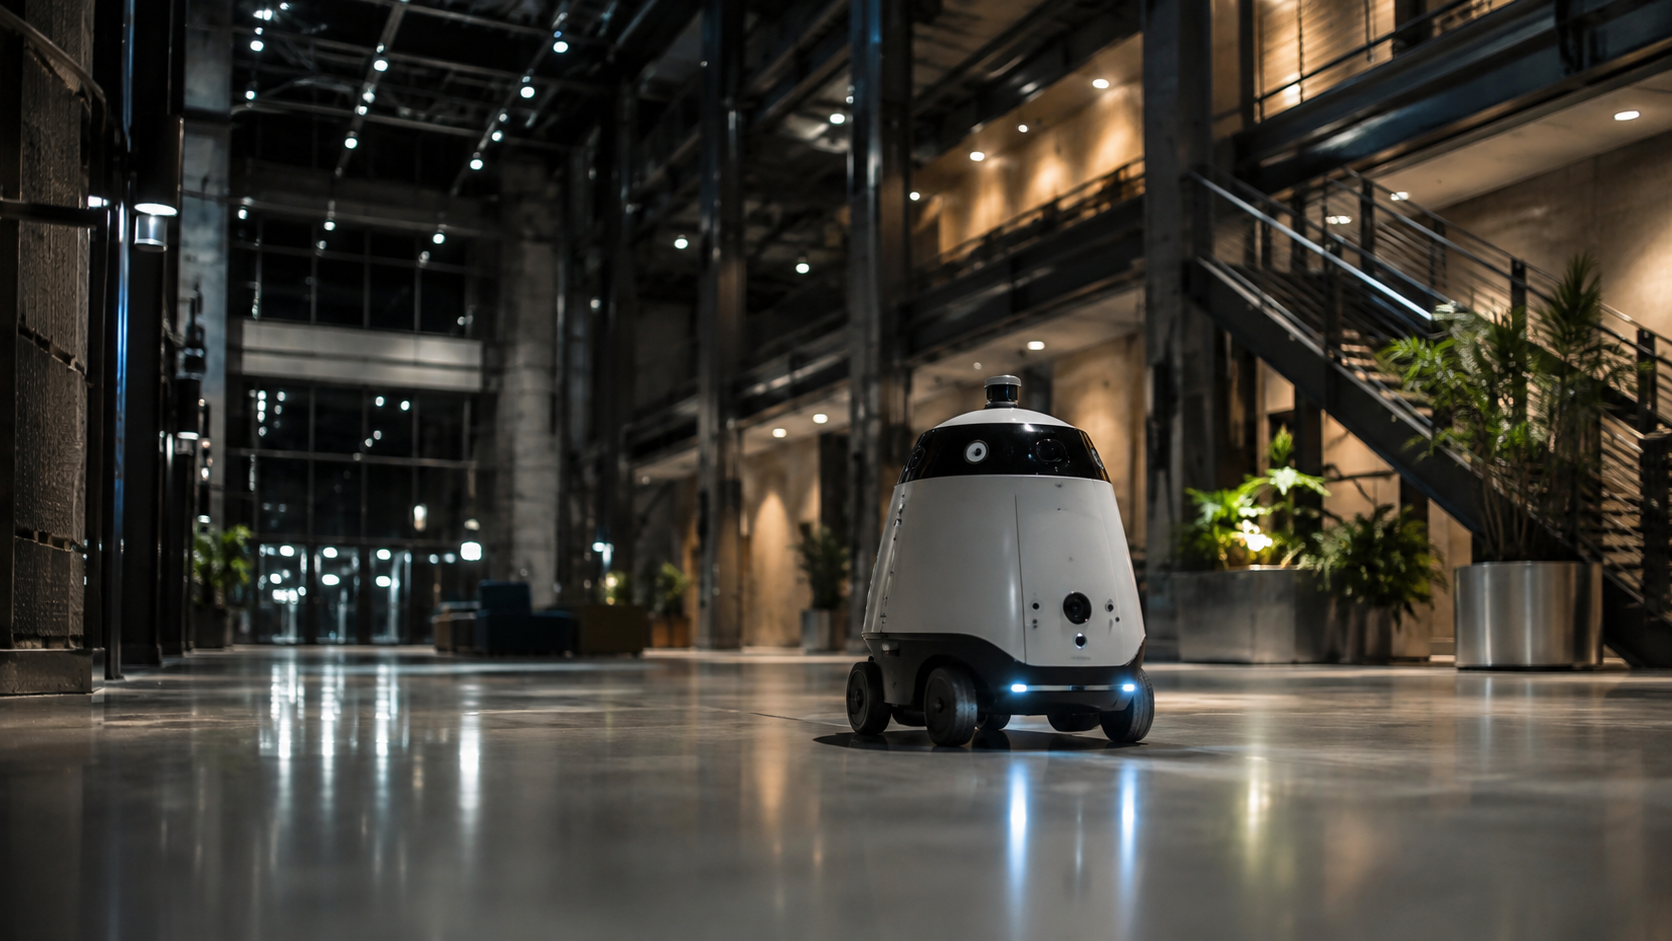
    Autonomous security robots attract attention because they make physical security visible, but their real value depends on operational fit. A robot is not automatically useful simply because it can patrol. The strongest deployments are those in which mobility solves a specific coverage, inspection or staffing problem.

    Robots can carry visible-light cameras, thermal imaging, microphones, environmental sensors, LiDAR and two-way communications. They can follow scheduled patrol routes, stop at checkpoints, record evidence and alert operators when analytics detect an anomaly.

    Large warehouses, data-center campuses, parking facilities, industrial plants and logistics yards are among the environments where robotic patrol can make sense. These sites often have long repetitive routes, predictable surfaces and many assets that benefit from frequent inspection.

    The technology is less convincing in cluttered public environments, complex stairways, heavy pedestrian traffic or areas with constantly changing obstacles. Weather, ramps, curbs, doors and elevators can also limit mobility.

    Robots should not be evaluated primarily by appearance. Buyers should examine uptime, docking reliability, navigation accuracy, battery endurance, sensor quality, cyber security, remote takeover, API integration and how frequently a human must intervene.

    The best architecture connects robotic patrol with existing security systems. A robot can be dispatched to a door alarm, thermal anomaly or perimeter event, then stream video into the command center. This turns the robot into a mobile verification platform rather than a standalone novelty.

    Autonomous robots are unlikely to replace security personnel broadly. They can, however, take over repetitive observation tasks, extend sensor coverage and give operators a mobile viewpoint when deployed in environments that match their capabilities.

  • Autonomous Drones for Perimeter Patrol

    Autonomous Drones for Perimeter Patrol

    Autonomous drones are moving from experimental security projects toward practical perimeter-monitoring tools. Instead of being manually flown for every mission, an autonomous system can launch from a docking station, follow a predefined route, inspect points of interest and return for charging with limited operator involvement.

    The value is not that drones replace fixed cameras or guards. Their value is mobility. A drone can investigate an alarm, inspect a remote fence section, view the far side of a building or patrol terrain that would require many fixed camera positions.

    Modern systems combine navigation, obstacle avoidance, geofencing, video analytics and fleet-management software. Thermal payloads can improve night operations, while high-resolution visible cameras provide identification and documentation.

    Autonomy introduces new design requirements. The drone must operate safely around structures, power lines, people and changing weather. Communications loss, GPS degradation, emergency landing and cyber security must all be addressed. Docking stations also become critical infrastructure because they provide charging, data transfer and environmental protection.

    Security workflows are most effective when drone missions are triggered by other sensors. A fence alarm, radar track or fiber-optic detection event can automatically create a task for a drone to inspect the location. The resulting video can then be displayed in the same command platform used for fixed cameras.

    Regulation remains a major factor. Beyond-visual-line-of-sight operations, autonomous missions and flights near populated or restricted areas may require specific approvals. Organizations should treat aviation compliance as part of system design from the beginning.

    Autonomous drones are best understood as mobile sensors within a layered perimeter system. Their strongest role is verification, inspection and rapid situational awareness across large or difficult sites.

  • Tethered Drones for Industrial Site Monitoring

    Tethered Drones for Industrial Site Monitoring

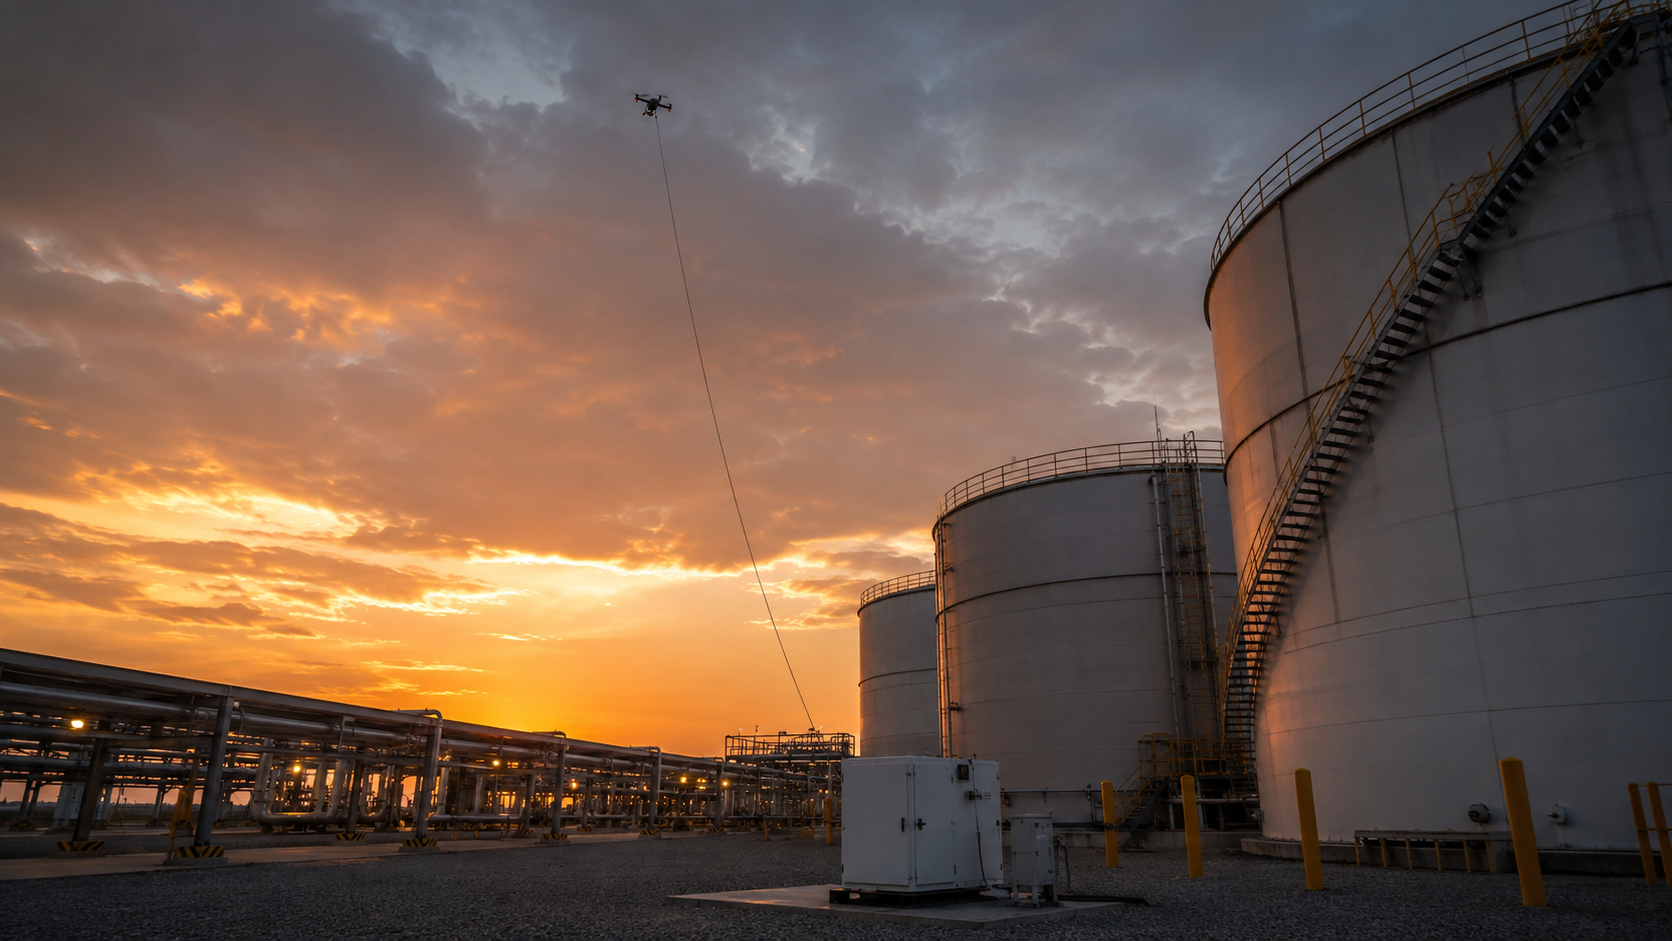
    Tethered drones occupy an unusual position between fixed surveillance towers and free-flying unmanned aircraft. Connected to the ground by a cable that can provide power and communications, a tethered drone can remain airborne for extended periods while carrying cameras, thermal sensors, communications equipment or other payloads.

    For industrial security, the main advantage is persistent elevated observation. A drone positioned tens of meters above a refinery, port, mine, pipeline construction zone or temporary event can see over fences, buildings and terrain that would block ground cameras. Because power is supplied from the ground, endurance can be measured in hours or days rather than the battery life of a conventional drone.

    The tether can also provide a secure high-bandwidth data path, reducing dependence on wireless links. This is useful where video quality, cyber security or RF congestion is a concern.

    Tethered systems still have operational limits. Wind, lightning, aviation restrictions, tether management and safe operating areas must be considered. They are not suitable everywhere, and the aircraft remains a visible physical asset that requires maintenance and procedures.

    Their strongest use case is usually temporary or semi-permanent overwatch: construction projects, incident response, large industrial shutdowns, border posts, temporary perimeter expansion or remote facilities where installing a tower would take longer.

    Tethered drones should be integrated with the wider security system rather than treated as standalone cameras in the sky. Video can feed the VMS, analytics can monitor defined zones and command-center operators can correlate aerial views with ground sensors.

    As industrial sites seek flexible surveillance coverage, tethered drones provide a middle ground between permanent infrastructure and mobile airborne patrol.

  • Acoustic Drone Detection: Where It Works and Where It Fails

    Acoustic Drone Detection: Where It Works and Where It Fails

    Acoustic drone detection uses microphones or microphone arrays to listen for characteristic sound signatures produced by propellers and electric motors. Unlike radar or active radio systems, acoustic sensors are passive. They do not transmit energy and can sometimes detect drones that are flying autonomously without an obvious RF control link.

    The technology is attractive because it can be compact, relatively easy to deploy and useful as a supplementary sensor. Algorithms compare incoming audio with trained signature libraries and may estimate direction of arrival when multiple microphones are used together.

    Its main limitation is range. Sound attenuates quickly, especially in wind, rain or complex terrain. Urban areas, highways, factories, airports and ports generate substantial background noise that can mask drone signatures or create false detections. The same drone may also sound different depending on payload, propeller type, speed and distance.

    Acoustic detection therefore works best in quieter environments or as part of a multi-sensor architecture. A radar track can be strengthened by an acoustic confirmation, while an acoustic cue can direct a camera toward a suspected target. It is generally less suitable as the sole primary detector for large critical sites.

    System evaluation should focus on measured performance in the actual environment rather than laboratory range claims. Buyers should test wind conditions, machinery noise, vehicle traffic and different drone types. They should also examine how the acoustic layer integrates with radar, RF and video systems.

    Acoustic sensing has a legitimate role in drone awareness, but its strength comes from complementing other technologies. Used correctly, it adds another independent source of evidence; used alone, it can be vulnerable to environmental conditions that are difficult to control.

  • Critical Infrastructure Airspace Monitoring

    Critical Infrastructure Airspace Monitoring

    Critical infrastructure security traditionally focused on fences, gates, cameras and ground-based intrusion detection. Drones have added a new dimension: the low-altitude airspace above a facility can now be used for observation, inspection, accidental overflight or unauthorized activity. Power plants, refineries, substations, ports, data centers and water facilities increasingly treat airspace awareness as part of physical security.

    A typical architecture combines radar, RF sensing, optical or thermal cameras and a command platform. Radar supplies range, direction and track history. RF monitoring can provide protocol-level clues when a drone is actively communicating. Cameras verify the target and create evidence. Sensor fusion then combines these data points into a single operational track.

    Risk is highly site-specific. A drone above a large solar farm presents a different concern from one approaching a high-voltage substation, LNG terminal or nuclear facility. Security teams should therefore define protected zones, alert thresholds and escalation rules around critical assets rather than using one uniform alarm policy.

    Integration with existing systems is essential. When an airspace event is detected, nearby perimeter cameras can be cued automatically, incident-management software can create a case and operators can correlate the drone’s route with ground activity. This is especially valuable when the airspace event is part of a broader security incident.

    Environmental design is also important. Industrial facilities contain steel structures, pipes, cranes, electromagnetic noise and moving machinery. These conditions affect radar, RF and camera performance. Site surveys and real-world testing should therefore be part of procurement.

    The most useful outcome is not a separate drone console, but a unified picture that shows what is happening on the ground and in the air. As critical infrastructure becomes more instrumented, low-altitude airspace monitoring is likely to become another standard layer of integrated physical security.

  • Airport Drone Detection Systems

    Airport Drone Detection Systems

    Airports face one of the most demanding drone-detection environments. A small unmanned aircraft can create operational disruption around runways, approach paths and terminal areas even when there is no malicious intent. The challenge is not simply to detect an object in the sky, but to determine whether it represents a credible risk quickly enough for airport operators to act.

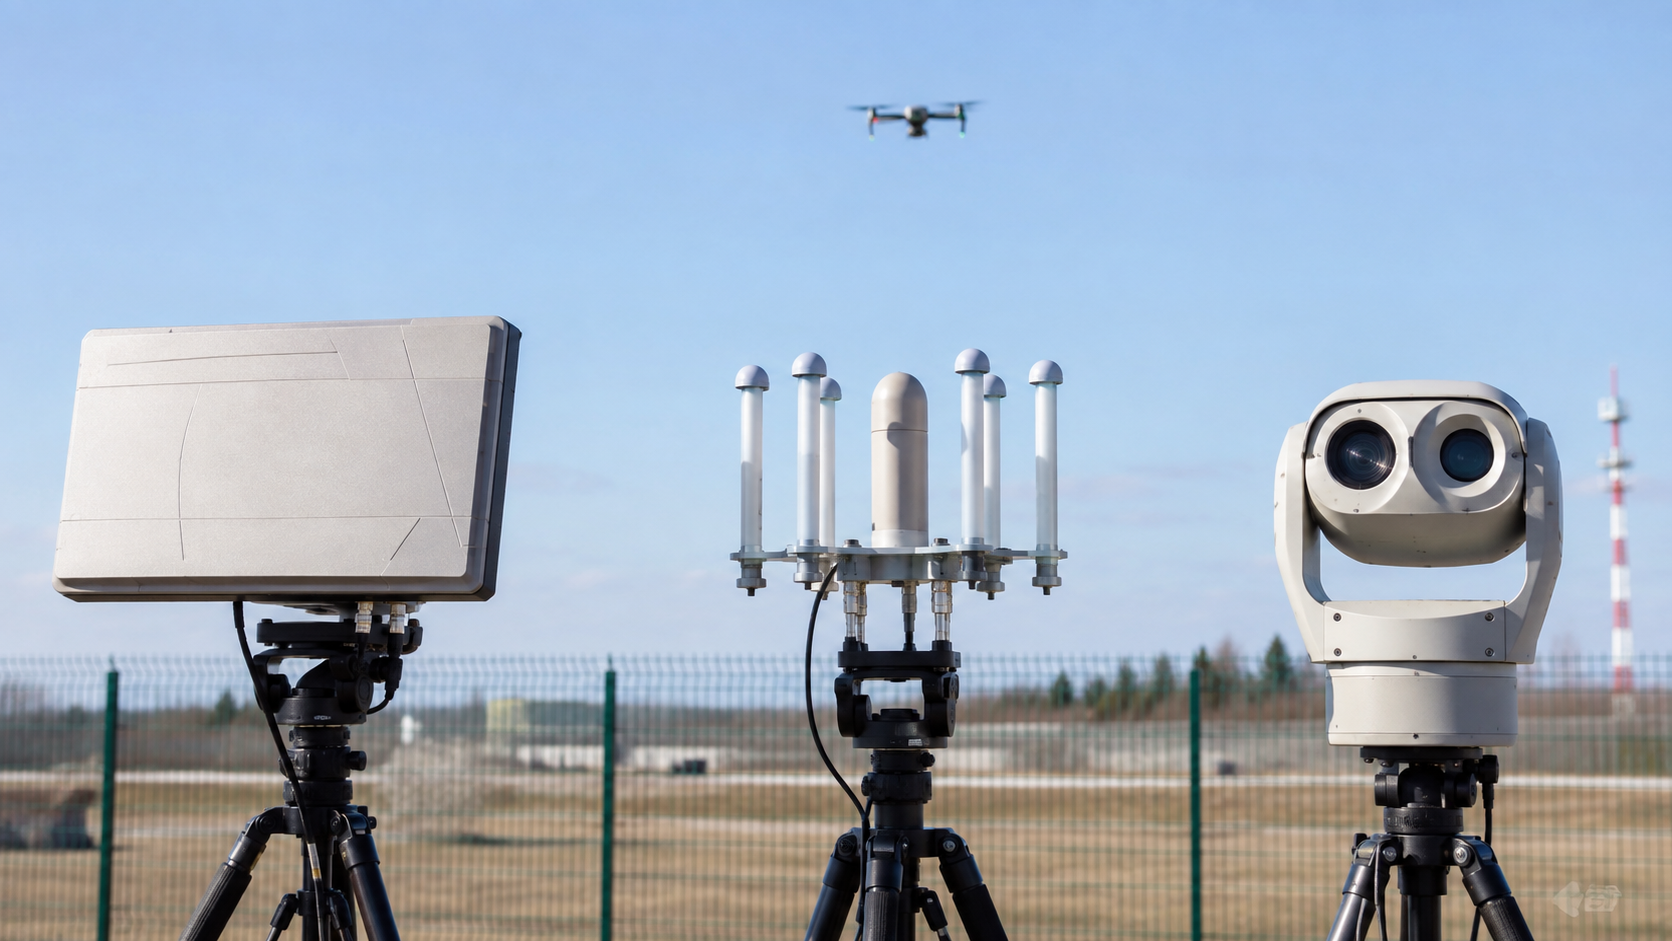
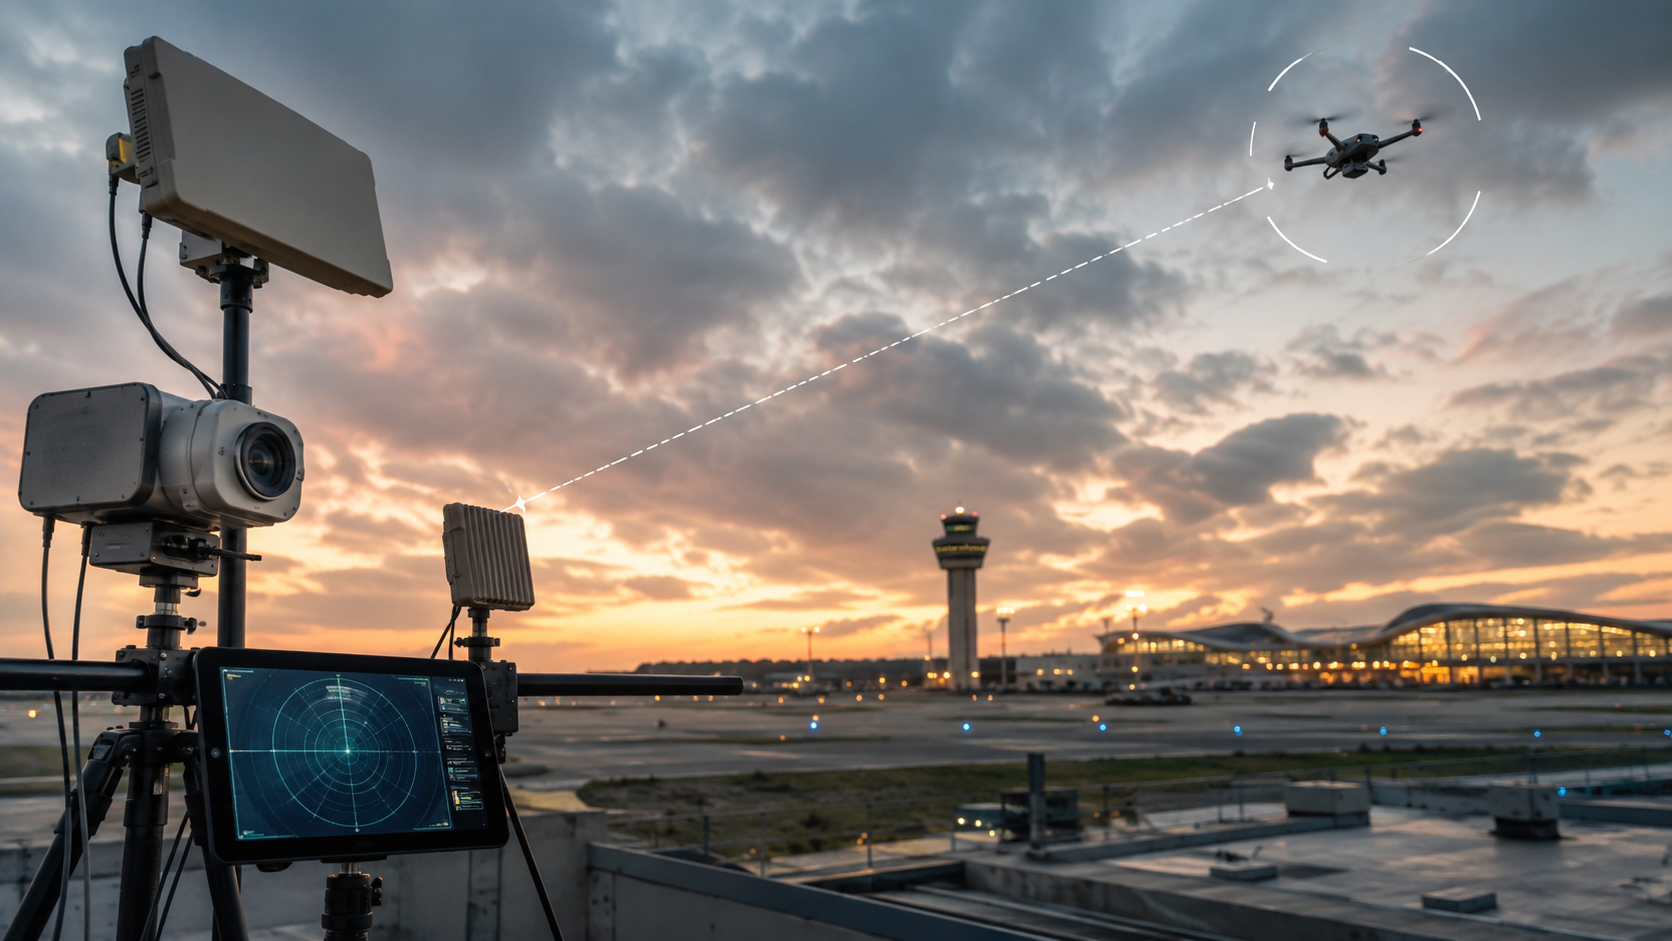
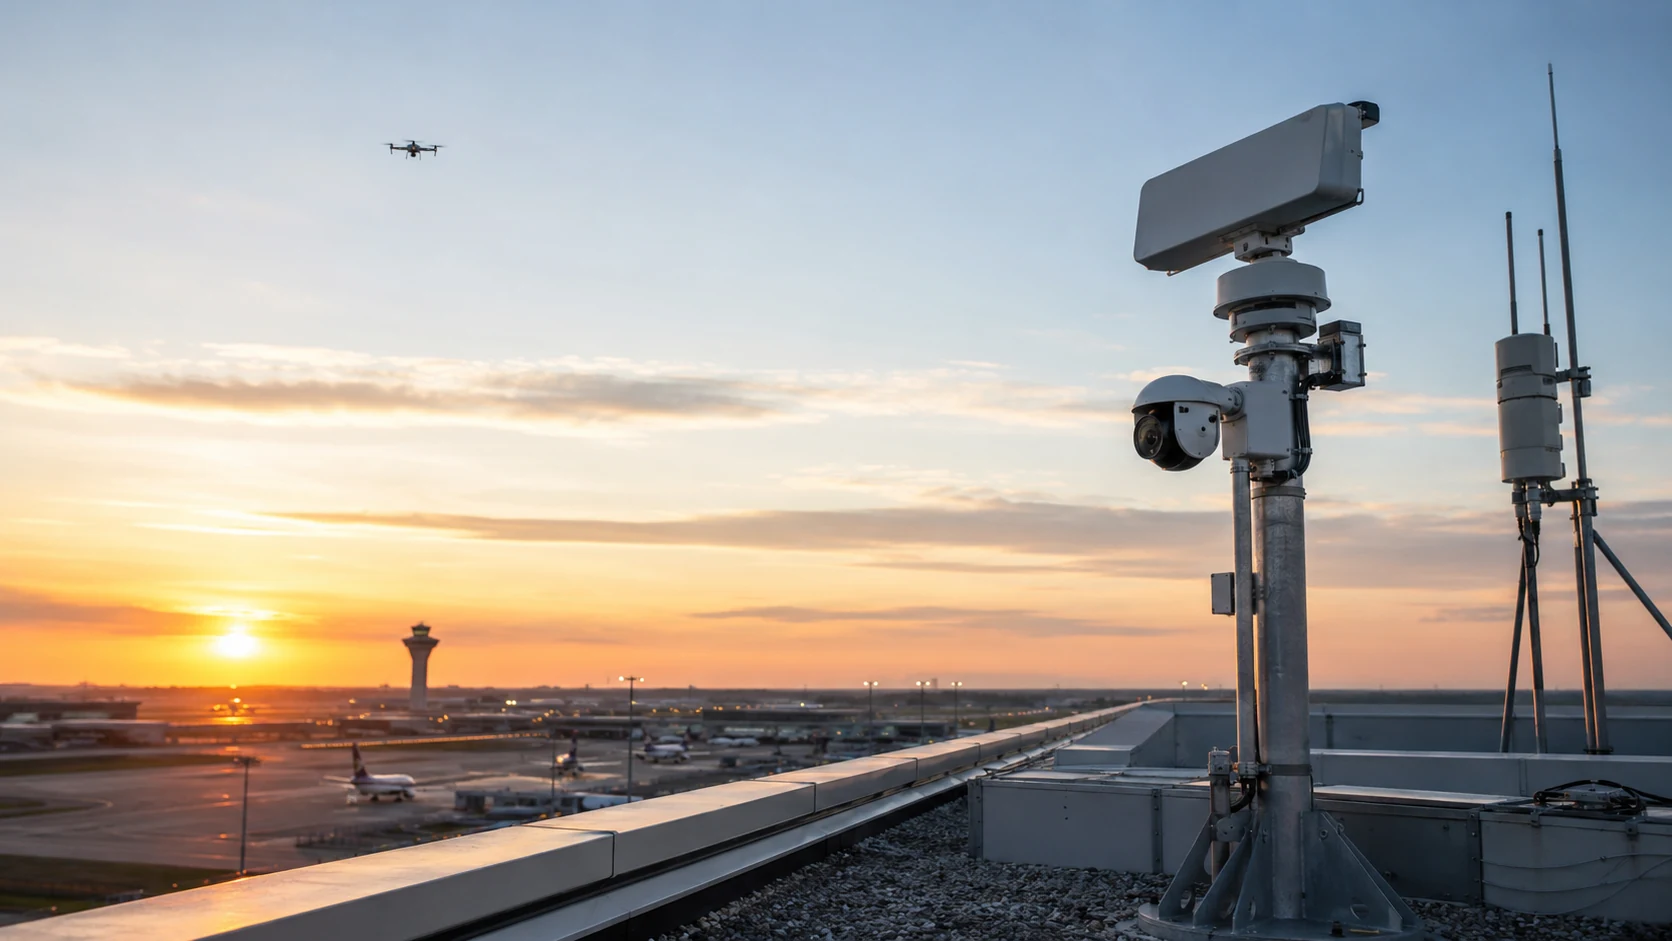
    Modern airport systems normally combine short- and medium-range radar, radio-frequency monitoring, electro-optical cameras and thermal imaging. Radar provides persistent coverage and track information. RF sensors can identify known command links or protocols. Cameras then provide visual confirmation and evidence. Because airports already contain extensive radar, radio and navigation infrastructure, careful frequency planning and site engineering are essential.

    Coverage design matters as much as sensor selection. A system should consider runway approaches, terminal airspace, parking aprons, perimeter zones and nearby public areas. Terrain, hangars, control towers and other structures can create blind spots. Multiple sensors positioned around the airport are often required to achieve useful low-altitude coverage.

    False alarms are another major concern. Birds, ground vehicles, construction equipment and conventional aircraft can all produce confusing signatures. Good systems use track behavior, micro-Doppler analysis and sensor fusion to improve classification. The objective is not to eliminate every false positive, but to reduce them to a level at which operators continue to trust the system.

    Drone detection must also integrate with airport operations. A verified track may need to be shared with the airport operations center, air traffic stakeholders, police or other authorized responders. Automated camera cueing and geofenced alert zones can help prioritize drones that are moving toward a runway or other sensitive area.

    Detection should be separated from mitigation. Active countermeasures may be restricted by aviation and communications law, and authority varies by country. For many airports, the most important capabilities are early detection, reliable tracking, evidence preservation and a clear operational response plan.

    The best airport drone-detection architecture is therefore layered, site-specific and tightly integrated with existing safety and security procedures. The goal is not simply to see drones. It is to create a dependable low-altitude airspace picture that supports fast, proportionate decisions.

  • Counter-UAS Detection: How Layered Airspace Awareness Works

    Counter-UAS Detection: How Layered Airspace Awareness Works

    Counter-UAS programs begin with awareness. Before any organization can respond to an unauthorized drone, it must first detect, classify and track the object with enough confidence to support a decision. That is why modern counter-UAS architecture is increasingly built around layered sensing rather than a single device.

    The Detection Layer

    The first layer is discovery. Security radar is frequently used because it can search a wide area continuously and provide position, speed and trajectory. RF sensors can add information about command links or known drone protocols. Acoustic arrays may contribute in short-range environments, while optical and thermal cameras provide visual confirmation.

    Each sensor has weaknesses. Radar can struggle with clutter and small non-drone objects. RF sensors may miss autonomous aircraft. Cameras need line of sight. Acoustic performance changes with wind and background noise. Layering reduces dependence on any one technology.

    Classification and Correlation

    Raw detections are not the same as actionable intelligence. A command platform must correlate data from different sensors and decide whether several observations represent the same target. Modern systems increasingly use machine learning, micro-Doppler analysis and track behavior to distinguish drones from birds, vehicles and other objects.

    The most useful output for an operator is not five separate alarms. It is one track with confidence, location, direction, speed and supporting evidence.

    Visual Verification

    After a radar or RF system detects a target, a pan-tilt camera can be automatically cued toward the coordinates. Daylight or thermal imagery can then help an operator understand what is in the air and whether the object is approaching a protected zone.

    This sensor-to-camera handoff is one of the most important features of an integrated counter-UAS system because it turns machine detection into human-verifiable situational awareness.

    Protected Zones and Rules

    Effective systems use geofenced zones instead of treating every drone equally. A drone several kilometers away may be informational. The same drone entering a runway approach, prison boundary or power-plant exclusion zone may trigger a higher-priority workflow.

    Rules can consider altitude, direction, speed, dwell time and proximity to sensitive assets. This allows operators to focus on behavior rather than simply counting airborne objects.

    Integration with Security Operations

    Counter-UAS should not exist as a separate island. Events can be integrated with VMS, access control, incident management, maps and command-center software. A drone approaching a substation, for example, can automatically bring nearby cameras onto screen and create an incident record.

    This unified workflow is particularly important at airports, critical infrastructure, ports, correctional facilities and large campuses where operators already manage many security systems.

    Detection Is Not Mitigation

    It is important to separate detection from active mitigation. Technologies that interfere with, take control of or physically defeat a drone are subject to significant legal and regulatory restrictions in many jurisdictions. A commercial security organization may be allowed to detect and document activity without being legally authorized to disrupt the aircraft.

    For that reason, system design should start with legal authority, response procedures and evidence requirements, not only hardware specifications.

    The Future of Airspace Awareness

    Counter-UAS detection is evolving into low-altitude airspace intelligence. Sensor fusion, edge AI, improved radar classification and automatic camera cueing are reducing false alarms and improving operator confidence. As drones become more autonomous, systems will increasingly need to detect physical behavior even when no conventional RF link is present.

    The strongest counter-UAS architecture therefore follows a layered principle: discover with multiple sensors, correlate the evidence, verify visually, prioritize by risk and integrate the result into the wider security operation.

  • Drone Detection Technologies: Radar, RF, Optical & Acoustic Explained

    Drone Detection Technologies: Radar, RF, Optical & Acoustic Explained

    Small unmanned aircraft have changed the way organizations think about perimeter security. A fence can define a property boundary, but it does not protect the airspace above it. Airports, power plants, ports, data centers, prisons, logistics hubs and other sensitive sites increasingly need systems that can discover, classify and track low-flying drones before an operator can make a decision.

    There is no single universal drone detector. Modern counter-UAS awareness systems normally combine several sensing methods because each technology sees a different part of the problem.

    Radar

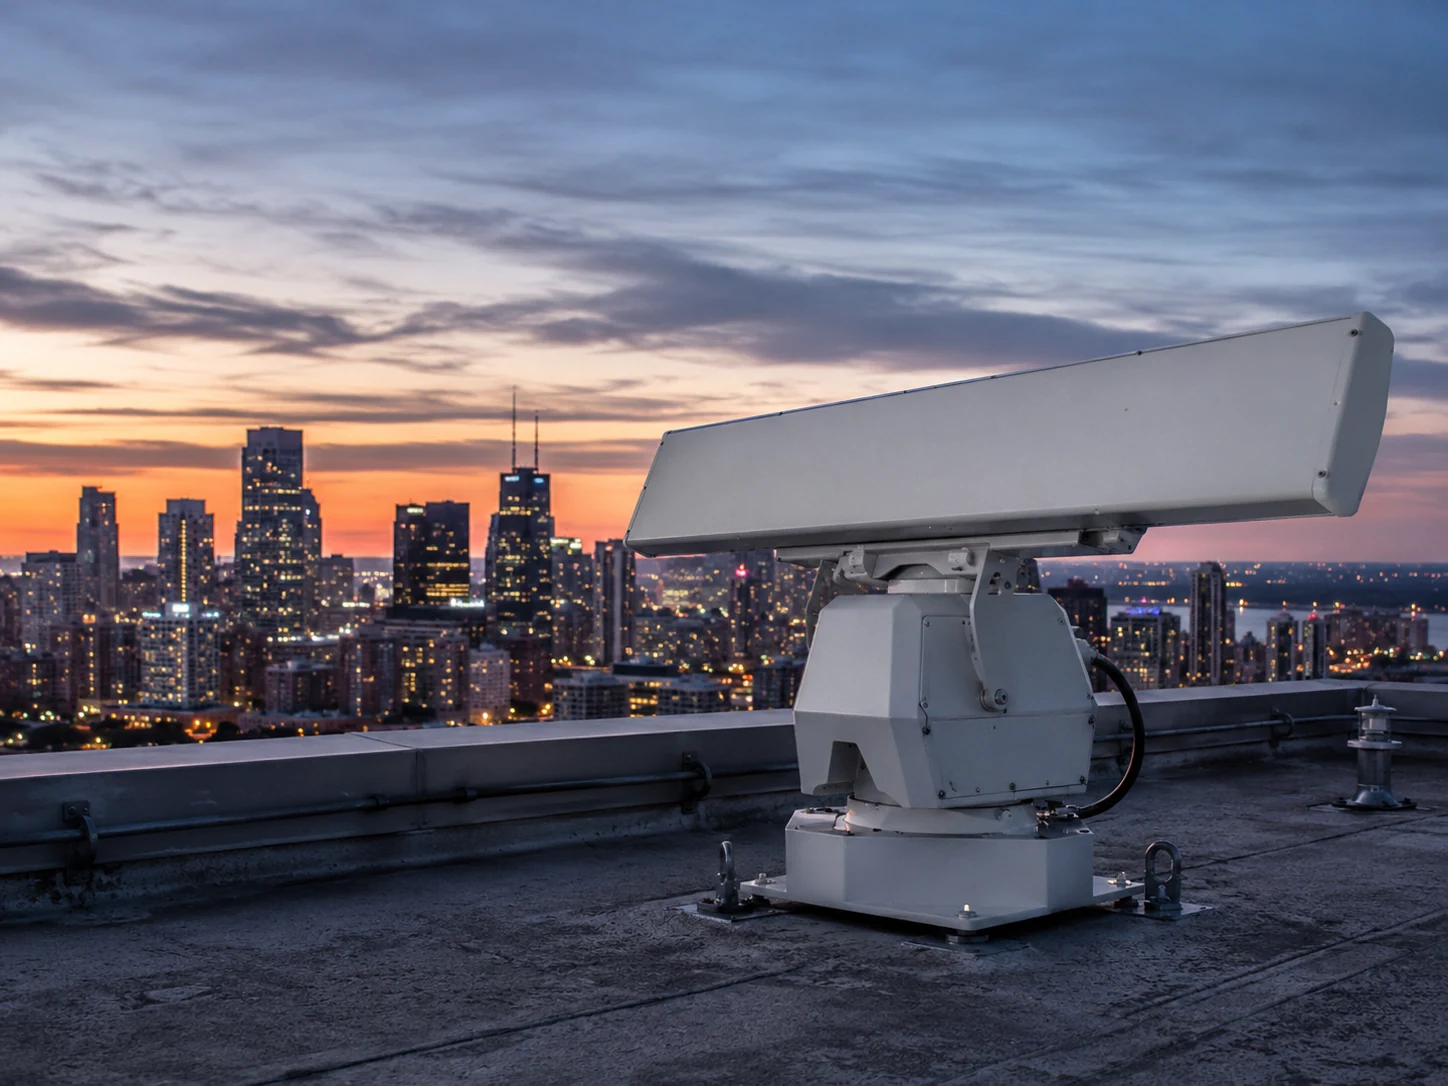
    Radar is one of the most important tools for persistent airspace surveillance. It transmits radio energy and analyzes reflections from objects in the monitored area. Security radars designed for small targets can detect and track drones at distances where conventional cameras may not yet provide useful imagery.

    Radar works day and night and does not depend on visible light. It can also provide range, direction, speed and track history. Its weakness is classification. Birds, clutter and moving machinery can create difficult signatures, so modern systems use micro-Doppler processing and machine-learning models to improve discrimination.

    RF Detection

    Radio-frequency detection looks for communication signals between a drone and its controller or for telemetry emitted by the aircraft. When a known protocol is detected, an RF system may identify the drone family, approximate its direction and sometimes locate both aircraft and controller.

    RF sensing can be highly effective because it may recognize a drone before the aircraft enters visual range. However, autonomous drones, unusual frequencies, encrypted links or pre-programmed flights may reduce detection opportunities. RF monitoring is therefore strongest when used as one layer rather than the only sensor.

    Optical and Thermal Cameras

    Visible-light and thermal cameras provide something radar and RF sensors cannot: visual confirmation. A tracking camera can automatically point toward a radar or RF cue and give the operator an image of the object.

    Day cameras can provide detailed evidence in good conditions. Thermal cameras remain useful at night and in many low-contrast situations because they detect heat rather than reflected visible light. Long-range optical systems often use motorized pan-tilt units and high-magnification lenses to maintain the target after detection.

    Their limitations are familiar: fog, heavy rain, obstacles, glare and extreme distance can reduce usable detail. A camera is usually most effective after another sensor has already told it where to look.

    Acoustic Detection

    Acoustic arrays listen for characteristic propeller and motor signatures. They are passive and do not emit radio energy, which can be useful in sensitive environments. Acoustic sensors can also help detect drones that do not transmit recognizable RF signals.

    The challenge is environmental noise. Wind, vehicles, machinery, aircraft and urban activity can mask or imitate signatures. Detection range is generally shorter than radar, so acoustic sensing is usually a supplementary layer.

    Why Sensor Fusion Matters

    The strongest architecture combines these technologies. Radar may discover an unknown target. RF analytics may identify the protocol. A camera may provide visual verification. Acoustic sensing may add confidence when the RF link is absent. The command platform then correlates the tracks into one operational picture.

    This approach reduces false alarms because the system is not asking a single sensor to make every decision. It also improves resilience: if one technology performs poorly because of weather, terrain or interference, another layer may still provide useful information.

    What Buyers Should Evaluate

    Detection range alone should never determine a procurement decision. Organizations should examine minimum target size, altitude coverage, update rate, clutter performance, false-alarm behavior, weather tolerance, cyber security, integration with VMS and command platforms, data retention, operator workload and legal constraints.

    The site survey is equally important. A sensor that performs well on a flat test field may behave differently beside buildings, cranes, hills, transmission lines or heavy RF activity.

    The Direction of the Market

    Drone detection is moving from isolated specialty equipment toward integrated airspace-awareness platforms. AI classification, edge processing, automated sensor cueing and unified command software are making it possible to treat the low-altitude air domain as another layer of physical security.

    For most critical sites, the practical lesson is simple: reliable drone awareness comes from layered sensing, not from a single detector. Radar, RF, optical, thermal and acoustic technologies are most powerful when they complement one another and present operators with one clear, verified track.